
Why Real-Time Systems Fail in Late-Stage Testing
Real-time systems are often validated extensively during development. Simulation environments are used to model behavior, test control algorithms, and evaluate system responses under a range of conditions.
Despite this, many systems that perform as expected during early validation encounter issues during integration, system testing, or field trials.
These failures are rarely caused by incorrect logic alone. More often, they are the result of timing behavior, system interaction, and real-world execution constraints that were not fully captured earlier in the development process.
Understanding why these issues emerge and how to identify them earlier is critical for improving system reliability and reducing development risk.
Why Systems Appear Stable Early
Simulation is a foundational tool in system development. It allows engineers to:
- validate guidance, navigation, and control (GN&C) algorithms
- model system behavior under different conditions
- iterate quickly without hardware dependencies
In these environments, systems often behave predictably because:
- execution timing is controlled or abstracted
- hardware interaction is simplified
- system load is limited or idealized
This makes simulation highly effective for functional validation and early-stage design.
However, as systems move closer to deployment, additional factors begin to influence behavior.
Where Late-Stage Failures Come From
Failures that appear during integration or testing are typically not new they are previously unobserved behaviors.
These behaviors often originate from three areas: timing, latency, and system interaction.
1. Timing Variability
In real-world systems, tasks must execute within specific time windows. Variability in scheduling often referred to as jitter can affect how systems respond to inputs.
Even small variations can lead to:
- control instability
- inconsistent system responses
- degraded performance
If timing behavior is not accurately represented during validation, these issues may not be detected until later stages.
2. Latency and System Response
Latency refers to the delay between an input (such as a sensor signal) and the corresponding system response.
In real-time systems, latency is influenced by:
- interrupt handling
- task scheduling
- communication delays
- system load
In simulation environments, latency is often simplified or minimized. When real-world constraints are introduced, system behavior may change.
3. Integration Complexity
Modern systems are composed of multiple subsystems that must operate together under real-time constraints.
Failures often occur at the interfaces between components, where:
- timing dependencies exist
- data must be synchronized
- communication delays affect behavior
Simulation alone may not fully capture these interactions, especially when hardware is not part of the validation loop.
The Role of Simulation Fidelity
Simulation is not the source of these issues it is a question of fidelity.
As systems progress through development, validation environments must more accurately reflect:
- real-world timing behavior
- hardware interaction
- system-level dependencies
Improving simulation fidelity allows engineers to observe behaviors that would otherwise remain hidden until later stages.
Extending Validation with Real-Time Execution
Understanding whether a system is hard or soft real to improve fidelity, simulation environments are extended with:
- real-time execution constraints
- deterministic scheduling
- controlled system timing
This ensures that system behavior reflects how software will perform under operational conditions.
Deterministic systems allow engineers to:
- separate system behavior from execution variability
- reproduce behavior consistently
- analyze timing-related issues
Incorporating Hardware-in-the-Loop (HIL)
Real-Hardware-in-the-loop (HIL) environments further extend simulation by introducing hardware or hardware-representative interfaces into the validation process.

This allows engineers to evaluate:
- sensor latency and signal timing
- hardware/software interaction
- closed-loop system behavior
By combining simulation with real-time execution and hardware interaction, HIL environments provide a more complete view of system performance.
Identifying Issues Earlier
When validation environments include both deterministic execution and hardware interaction, teams can identify issues earlier in development, including:
- timing instability
- latency-related behavior changes
- integration challenges between subsystems
This reduces the likelihood that issues will emerge during integration or field testing.
Missile TestBench: Supporting High-Fidelity Validation
Missile TestBench is a real-time hardware-in-the-loop simulation solution designed to enhance simulation environments with deterministic execution and hardware interaction.
It enables engineering teams to:
- execute GN&C systems under real-time constraints
- simulate inputs with realistic timing behavior
- integrate hardware into validation workflows
- analyze system timing and performance
By extending simulation into real-time validation, Missile TestBench helps teams identify system behavior earlier and with greater accuracy.
Built on Deterministic Real-Time Technology
Missile TestBench is built on the RedHawk Linux real-time platform and uses Simulation Workbench for automation and orchestration.
This architecture provides:
- deterministic scheduling
- low interrupt latency
- controlled system timing
- repeatable test conditions
These capabilities allow engineers to evaluate system behavior in a consistent and predictable environment.
From Late-Stage Failures to Early Insight
Late-stage failures are often the result of behaviors that were not observable during earlier validation.
By improving simulation fidelity and incorporating real-time and hardware-in-the-loop validation, engineering teams can:
- detect issues earlier
- reduce integration risk
- improve system reliability
- minimize costly rework
Real-time system failures rarely originate from a single cause. They are typically the result of interactions between timing, latency, and system complexity that become visible under realistic conditions.
Simulation remains essential, but as systems advance, validation environments must evolve to reflect real-world behavior more accurately.
By extending simulation with deterministic execution and hardware-in-the-loop techniques, teams can identify issues earlier and build systems that perform reliably when it matters most.
Related Articles
-
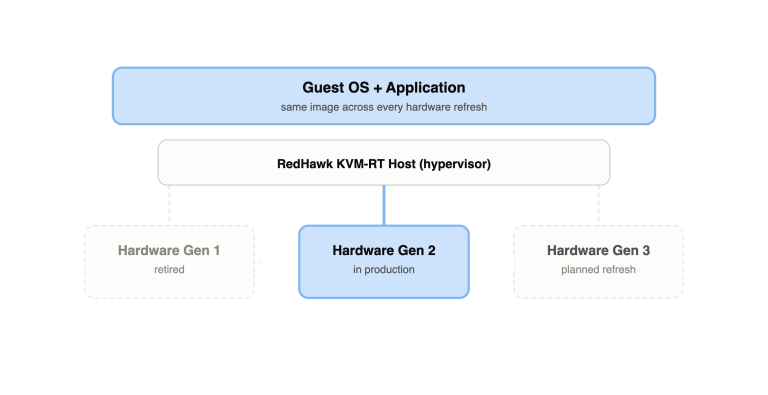
Preserving Legacy Real-Time Applications Through Virtualization
Preserving Legacy Real-Time Applications Through Virtualization Real-time applications often remain in service much longer than the hardware on which they were originally developed. Test systems, industrial controls, simulation environments, and data-acquisition platforms…
-
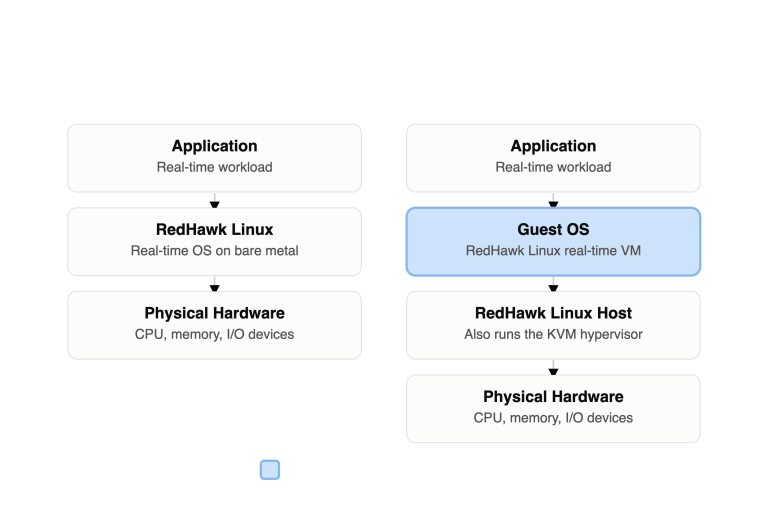
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application?
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application? Virtualization is now common in enterprise computing, but timing-sensitive systems introduce requirements that conventional IT workloads do not share. An application may…
-
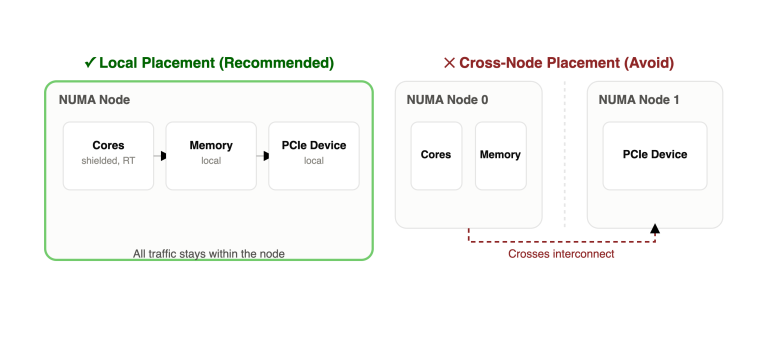
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines Running a real-time operating system inside a virtual machine does not automatically create a deterministic environment. The virtual machine still depends…