
Why RedHawk Linux Is the Go-To Real-Time OS for Time-Critical Applications
For developers building systems where milliseconds or microseconds matter, the choice of operating system is not trivial. General-purpose Linux distributions can introduce latency, jitter, and unpredictable scheduling delays that compromise system stability. This is where RedHawk Linux makes a difference.
RedHawk is a real-time Linux operating system designed specifically for time-critical environments. It combines the flexibility of Linux with deterministic performance, giving developers the control they need without sacrificing familiarity or compatibility.
Whether you’re building a flight simulator, an autonomous control platform, or a high-speed data acquisition system, RedHawk provides the foundation for consistent, predictable performance.
Determinism as a Design Principle
At the heart of RedHawk is its real-time kernel, engineered to minimize latency and ensure consistent response times under load. Unlike standard Linux kernels, which allow background processes and unpredictable scheduling, RedHawk focuses on timing precision.
Key features include:
- Support for POSIX-compliant real-time scheduling policies
- Fine-grained control over CPU affinity and interrupt handling
- Shielding to dedicate cores exclusively to real-time tasks
- High-resolution timers with microsecond accuracy
These features allow developers to build systems that respond within guaranteed timing constraints, even when under high CPU or I/O load.
Built on Familiar Foundations
RedHawk is based on other Linux ecosystems, which means it supports the similar tools, packages, and administration workflows used in many enterprise environments. This helps reduce the learning curve and makes it easier to integrate into existing toolchains.
Developers get the best of both worlds. They can work in a familiar Linux environment while benefiting from a kernel and scheduler tuned for real-time responsiveness.
RedHawk also supports a wide range of hardware platforms, including x86 multi-core processors, Intel Xeon systems, and GPUs. It is compatible with many I/O devices used in industrial, military, and research applications.
Real-Time Shielding and Isolation
One of the defining features of RedHawk Linux is its ability to isolate resources. Developers can shield one or more CPU cores so they are used only by selected processes. This prevents background services, interrupts, or kernel threads from interfering with real-time execution.
You can also bind interrupts to specific processors or remove them entirely from cores used for time-sensitive applications. This level of control is critical in systems that cannot afford delays caused by unexpected scheduling or contention.
Integration with the NightStar Toolset
RedHawk is fully compatible with Concurrent Real-Time’s NightStar tools. This includes:
- NightView for source-level debugging of live applications
- NightTrace for event timeline analysis
- NightTune for performance tuning and processor management
- NightSim for cyclic process scheduling
- NightProbe for non-intrusive data monitoring
These tools take full advantage of RedHawk’s real-time capabilities. They allow developers to observe and tune systems while they are running, without pausing execution or compromising timing behavior.
This level of integration simplifies the process of debugging, testing, and optimizing complex systems.
Use Cases Across Industries
RedHawk Linux is used in a wide range of applications where real-time performance is non-negotiable. Common examples include:
- Aerospace simulation and training systems
- Automotive HiL (Hardware-in-the-Loop) test platforms
- Industrial robotics and automation
- Defense systems and radar signal processing
- Medical devices requiring time-sensitive data handling
In each of these domains, developers rely on RedHawk to meet strict timing and safety requirements. Its performance is validated and benchmarked on supported hardware configurations to provide confidence during development and deployment.
Real-World Performance
RedHawk consistently delivers low worst-case latencies, often below 10 microseconds on certified hardware. This level of determinism allows developers to build systems with tight control loops and precise timing windows.
In real-world deployments, RedHawk has enabled customers to:
- Reduce timing jitter in control applications
- Maintain simulation frame rates under load
- Run concurrent tasks without loss of synchronization
- Safely integrate with real-world hardware inputs and outputs
Related Articles
-
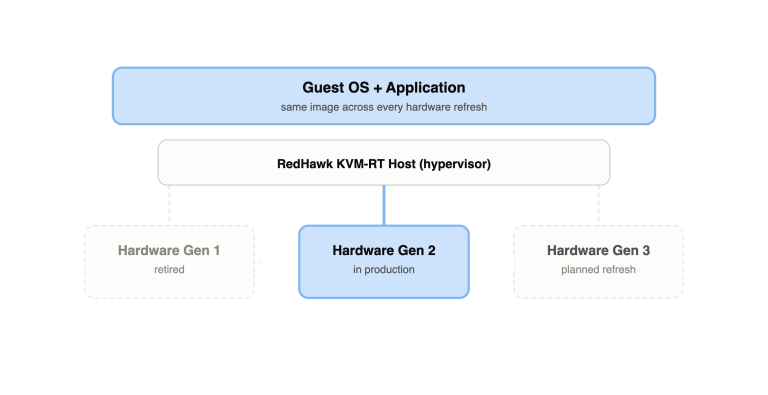
Preserving Legacy Real-Time Applications Through Virtualization
Preserving Legacy Real-Time Applications Through Virtualization Real-time applications often remain in service much longer than the hardware on which they were originally developed. Test systems, industrial controls, simulation environments, and data-acquisition platforms…
-
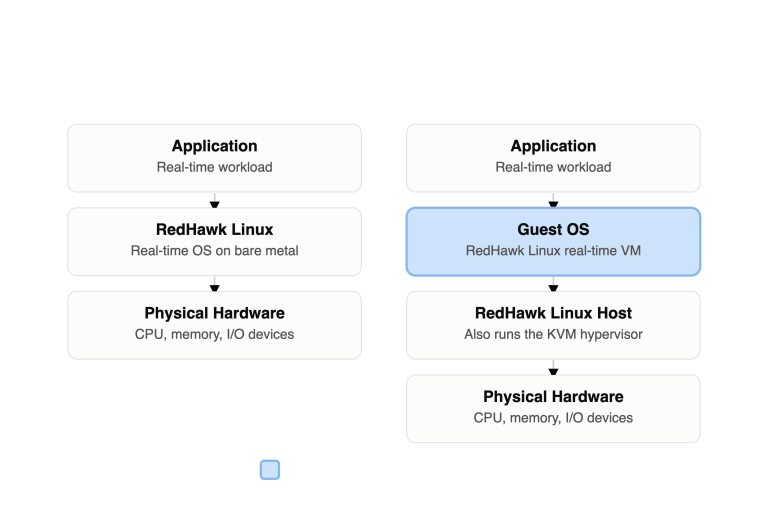
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application?
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application? Virtualization is now common in enterprise computing, but timing-sensitive systems introduce requirements that conventional IT workloads do not share. An application may…
-
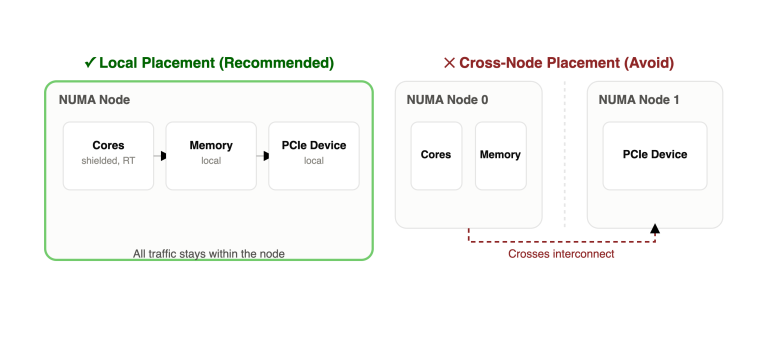
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines Running a real-time operating system inside a virtual machine does not automatically create a deterministic environment. The virtual machine still depends…