
Why Traditional Debugging Fails in Real-Time Systems
Traditional debugging techniques work well in many software environments. A developer can pause execution, inspect memory, step through code, and observe how the application behaves.
In real-time systems, that same process can create a completely different outcome.
- A timing issue disappears once execution is paused.
- A system behaves correctly while being debugged but fails during runtime.
- An intermittent issue becomes impossible to reproduce.
These situations are common in real-time environments because the act of debugging can change the behavior being investigated.

Real-Time Systems Depend on Timing
In general-purpose applications, execution timing is often flexible. Small delays typically do not affect overall functionality.
Real-time systems operate differently.
Many depend on:
- precise scheduling behavior
- predictable task execution
- controlled response timing
In these systems, timing is part of the system’s functionality not just its performance.
This is especially true in environments involving:
- control systems
- signal processing
- aerospace and defense applications
- hardware-in-the-loop (HIL) simulation
Even small timing changes can alter system behavior.
What Traditional Debugging Assumes
Most debugging tools are designed around a simple assumption:
The system can safely stop while the developer investigates it.
Traditional debugging techniques commonly include:
- breakpoints
- stepping through execution
- pausing processes
- inspecting state after an event occurs
In many applications, this is acceptable.
In real-time systems, it may invalidate the behavior you are trying to analyze.
When Debugging Changes the Outcome
Consider a system experiencing intermittent instability during runtime.
An engineer attaches a debugger and steps through execution, the instability disappears, and The issue was not fixed the timing behavior changed.
Pausing execution can affect:
- task scheduling
- interrupt timing
- synchronization between threads
- resource contention
As a result, the system no longer behaves as it did under normal conditions.
The Problem with Breakpoints in Real-Time Systems
Breakpoints are one of the clearest examples of this issue.
When a breakpoint is hit:
- execution stops
- task timing changes
- interrupts may be delayed
- system scheduling behavior is altered
In systems built on deterministic computing principles, this introduces artificial behavior that may not exist during actual operation.
For issues related to:
- jitter in real-time systems
- synchronization
- latency
- concurrency
breakpoints can make root cause analysis significantly more difficult.
Timing Issues Are Often the Real Problem
Many real-time failures are not caused by incorrect logic.
They result from:
- timing variability
- delayed interrupts
- scheduling contention
- resource conflicts between tasks
These behaviors are often intermittent and load-dependent.
For example:
Task executes normally under low load → System load increases → Interrupt delay increases slightly →
Control loop timing changes → System instability appears
This type of issue is difficult to diagnose if debugging tools disrupt execution timing.
Logging Has Limitations Too
Logging is often used as an alternative to stepping through code.
While useful, logging has tradeoffs:
- additional I/O overhead
- increased CPU usage
- altered timing behavior
Extensive logging can unintentionally introduce the very variability engineers are trying to measure.
This is why high-frequency logging is often avoided in time-sensitive environments.
A Different Approach: Observe While the System Runs
Real-time debugging requires a shift in mindset.
Instead of stopping execution, engineers focus on observing behavior continuously while the system operates normally.
This includes techniques such as:
- event tracing
- runtime monitoring
- non-intrusive analysis
These approaches preserve timing relationships while providing visibility into system behavior.
Why Event Tracing Works Better
Unlike traditional debugging, event tracing captures activity over time without halting execution.
This allows engineers to observe:
- task execution order
- interrupt activity
- timing relationships
- system-wide interactions
By analyzing sequences of events rather than isolated snapshots, engineers can identify patterns that traditional debugging often misses.

Real-Time Platforms Matter
The underlying platform also affects debugging accuracy.
Platforms such as real-time Linux environments provide:
- deterministic scheduling
- low and consistent interrupt latency
- CPU isolation capabilities
These features help maintain predictable behavior during analysis and validation.
Supporting Non-Intrusive Debugging with NightStar Tools
NightStar Tools are designed specifically for debugging and analyzing real-time systems without disrupting execution.
They provide capabilities for:
- source-level debugging
- event tracing
- runtime monitoring
- performance analysis
Because these tools operate with minimal intrusion, engineers can observe system behavior while preserving real-time characteristics .
This makes it easier to diagnose:
- intermittent timing issues
- synchronization problems
- latency-related behavior changes
that may not appear when using traditional debugging techniques.
What Engineers Should Watch For
When debugging real-time systems, it is important to consider whether the debugging process itself is influencing behavior.
Key indicators include:
- issues that disappear during debugging
- problems that only occur under load
- inconsistent timing behavior
- intermittent synchronization failures
These are often signs that timing not logic is the root cause.
Traditional debugging techniques were not designed for systems where timing behavior is critical.
In real-time environments, stopping execution can alter scheduling, timing relationships, and overall system behavior, making issues harder to reproduce and diagnose.
By using non-intrusive techniques such as event tracing and runtime monitoring, engineers can observe systems under realistic operating conditions and gain more accurate insight into system behavior.
Related Articles
-
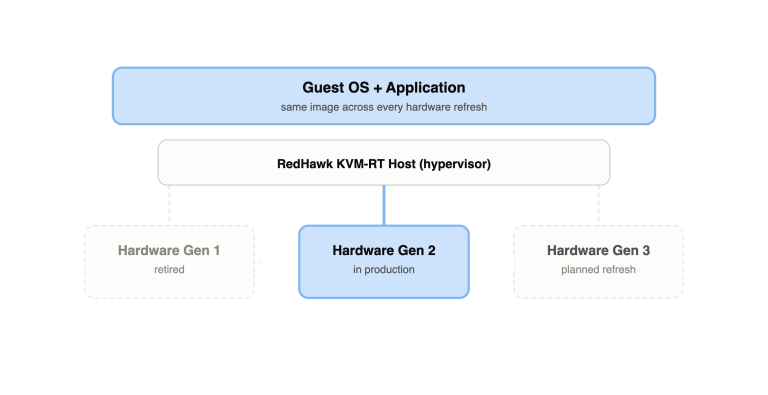
Preserving Legacy Real-Time Applications Through Virtualization
Preserving Legacy Real-Time Applications Through Virtualization Real-time applications often remain in service much longer than the hardware on which they were originally developed. Test systems, industrial controls, simulation environments, and data-acquisition platforms…
-
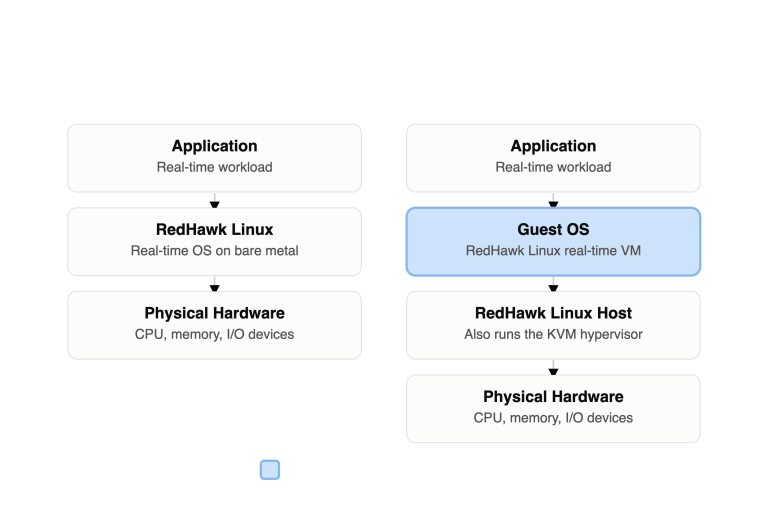
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application?
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application? Virtualization is now common in enterprise computing, but timing-sensitive systems introduce requirements that conventional IT workloads do not share. An application may…
-
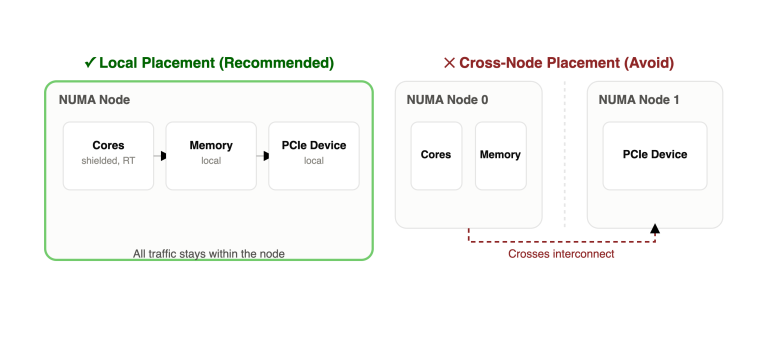
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines Running a real-time operating system inside a virtual machine does not automatically create a deterministic environment. The virtual machine still depends…