
How Real-Time Simulation Helps Prepare Mission-Critical Spaceflight Systems
NASA’s Artemis missions demonstrate why high-fidelity, deterministic simulation is essential for complex aerospace programs. Concurrent Real-Time technology helps support simulation environments where timing accuracy, repeatability, and system-level validation matter.
When Mission Performance Depends on Testing Before Flight
Spaceflight leaves little room for uncertainty. Before a launch system carries astronauts beyond low Earth orbit, engineering teams need to understand how software, hardware, control logic, guidance systems, sensors, and mission procedures will behave under demanding real-world conditions. That is why simulation is not just a development activity for modern aerospace programs. It is a mission-readiness discipline.
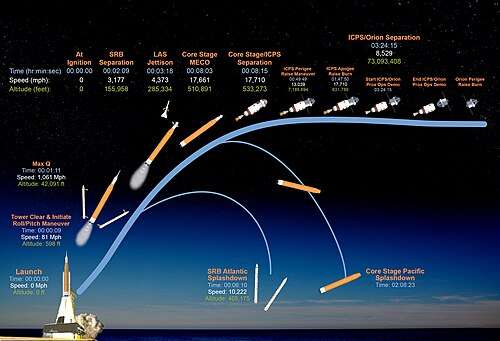
NASA’s Artemis II mission, the first crewed Artemis flight and a key step in the return to the Moon, showcased the importance of preparing complex systems through extensive test and simulation. Artemis II launched aboard NASA’s Space Launch System rocket with the Orion spacecraft and sent four astronauts on a mission around the Moon and back, validating systems and operations needed for future lunar exploration.
For programs of this scale, the ability to run mission scenarios again and again before flight helps engineers reduce risk, refine system behavior, and build confidence in the performance of the final mission architecture.
The Role of Real-Time Simulation in SLS Testing
A launch system as complex as SLS cannot be validated by conventional software testing alone. Engineers need simulation environments that can execute time-sensitive workloads predictably, preserve timing behavior, and allow teams to evaluate how systems interact under realistic conditions.
That is where deterministic real-time computing becomes critical. In simulation environments, timing fidelity matters because the timing of the test environment can affect the behavior being measured. If the platform introduces unpredictable latency, jitter, or scheduling variation, it can limit the value of the test results.
Concurrent Real-Time systems are used in high-performance real-time computing environments where simulation repeatability, timing accuracy, and system observability are essential. RedHawk Linux provides the deterministic real-time foundation, while tools such as NightStar support debugging, monitoring, tracing, scheduling, analysis, and tuning for time-critical Linux applications. For aerospace simulation teams, that combination helps create an environment where engineers can observe system behavior without disrupting the execution characteristics they are trying to validate.
Testing Thousands of Times Before It Matters Once
The value of simulation becomes especially clear when mission leaders describe the impact of repeated SLS testing. Joseph Pelfrey, former Director of NASA Marshall Space Flight Center, summarized the importance of this work in a statement shared with Concurrent Real-Time:
“Being able to test SLS thousands of times is one of the reasons it performed so well. It delivered Artemis with 99.7% accuracy, to within 100 yards of the exact planned destination in space.”
He also noted:
“The actual accuracy was 99.92%. The target altitude for Artemis II was an apogee of 975 NM and a perigee of 16 NM for initial Earth orbit.”
Those figures highlight an important point for aerospace and defense programs: the mission outcome is shaped long before the vehicle leaves the pad. The ability to test, analyze, tune, and repeat complex scenarios is part of what allows engineering teams to move from design confidence to operational confidence.
Why Determinism Matters in Aerospace Simulation
In real-time simulation, it is not enough for a system to be fast. It must be predictably fast. Aerospace test environments often involve multiple processors, high-speed I/O, control loops, hardware-in-the-loop components, and simulation models that must remain synchronized. When those elements interact, missed deadlines or timing inconsistency can affect the validity of the test.
Deterministic real-time platforms help teams maintain predictable execution across demanding simulation workloads. They also give engineers the ability to analyze performance, identify timing issues, and tune system behavior before those issues become mission risks.
This is especially important for programs involving guidance, navigation, and control; vehicle dynamics; avionics; sensor interfaces; and system-level mission simulation. In these environments, the test platform is not just running software. It is helping reproduce the timing conditions required to evaluate mission-critical behavior.
Visibility Without Disrupting Execution
One of the challenges in debugging and analyzing time-critical systems is that the act of observing the system can change the system’s behavior. Traditional debugging techniques may interrupt execution, alter timing, or make it harder to identify issues that only appear under real-time operating conditions.
Concurrent’s NightStar tools were developed for this kind of challenge. The toolset supports real-time debugging and analysis with minimal intrusion, helping engineers debug, monitor, trace, schedule, analyze, and tune time-critical Linux applications while preserving application execution behavior. Capabilities such as synchronized event tracing, cyclic application scheduling, data monitoring, and performance tuning help engineering teams understand what is happening across applications, operating system activity, CPUs, threads, interrupts, and timing-sensitive processes.
For SLS-class simulation environments, that level of visibility matters. Engineers need to see what happened, when it happened, and how different parts of the system interacted without compromising the timing behavior of the test itself.
From Simulation Confidence to Mission Confidence
The Artemis program reflects a broader reality across aerospace and defense: increasingly complex systems require increasingly disciplined test environments. As mission architectures become more software-defined, more interconnected, and more timing-sensitive, deterministic simulation becomes a critical part of engineering assurance.
Real-time simulation helps teams evaluate system behavior earlier, repeat tests more consistently, and analyze performance under conditions that better represent mission realities. When paired with powerful debugging and analysis tools, it gives engineers a clearer path from model validation to hardware-in-the-loop testing to integrated mission readiness.
For Concurrent Real-Time, supporting these kinds of environments is central to the company’s role in aerospace and defense. Whether the application involves launch system simulation, hardware-in-the-loop testing, high-speed data acquisition, or time-critical system analysis, the goal remains the same: provide the deterministic computing foundation engineers need when performance, timing, and mission success cannot be left to chance.
Related Articles
-

Preserving Legacy Real-Time Applications Through Virtualization
Preserving Legacy Real-Time Applications Through Virtualization Real-time applications often remain in service much longer than the hardware on which they were originally developed. Test systems, industrial controls, simulation environments, and data-acquisition platforms…
-

Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application?
Native Real-Time Linux vs. Real-Time Virtualization: Which Architecture Fits Your Application? Virtualization is now common in enterprise computing, but timing-sensitive systems introduce requirements that conventional IT workloads do not share. An application may…
-

How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines
How CPU Shielding, NUMA, and Interrupt Affinity Affect Real-Time Virtual Machines Running a real-time operating system inside a virtual machine does not automatically create a deterministic environment. The virtual machine still depends…